


 Chinese
 Spanish
 Russian
 Portuguese
 French
 German
 Indonesian
 Thai
 Vietnamese
 Arabic
 Italian
 Turkish
 Polish
 Japanese


A six-axis load cell resolves three force components and three moment components in a defined coordinate system. For a METRAVON enquiry, MV-LC0241 is the documented six-axis force/torque candidate: its product page identifies Fx, Fy, Fz, Mx, My and Mz, matched capacity sets and mV/V bridge outputs. Selection still needs the complete loading case, fixture and acquisition requirements. A product labelled for complex loading is not sufficient evidence of six independent measurements.
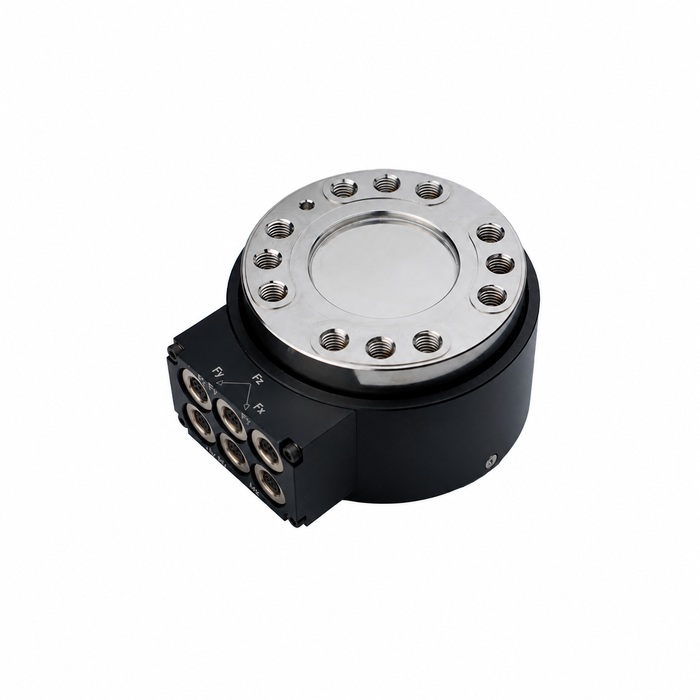
Select a complete MV-LC0241 force and moment set
Keep the MV-LC0241 published rating sets together. Each row below is one listed combination, rather than an independent menu of force and moment maxima. Submit simultaneous loads, fixture weight, preload and operating transients before approving a configuration.
| Fx / Fy | Fz | Mx / My | Mz |
|---|---|---|---|
| 2 kN | 10 kN | 150 N m | 150 N m |
| 5 kN | 25 kN | 350 N m | 250 N m |
| 10 kN | 50 kN | 700 N m | 500 N m |
Separate the largest load the assembly can encounter from the smallest force or moment that must be distinguished. A capacity that survives a peak may not provide the required low-load uncertainty through the selected amplifier and fixture. Request an assessment at the actual working loads; do not turn the individual axis ratings or an overload percentage into permission to apply every maximum simultaneously.
The coordinate origin changes the reported moment
Consider an illustrative 20 N force applied perpendicular to a 0.05 m lever arm from the sensor origin. The associated moment magnitude is 1 N m. Move the reporting origin and the moment components can change even though the physical force is unchanged. This example explains geometry; it is not a model rating, a measured METRAVON result or evidence that the published capacity sets suit a 20 N task.
Mark the sensor origin, tool reference point, mounting faces and positive directions on one drawing. The acquisition software must use the same convention as the calibration. For a robot or test fixture, changing tool length or an adapter offset changes the moment transformation. Record that geometry with the test result rather than changing only a display label.
A six-axis load cell needs six defined signal channels
MV-LC0241 lists bridge sensitivities that differ between the force and moment channels. The receiving equipment needs suitable excitation, low-level inputs and a documented conversion from signals to engineering values. A standard PLC current input does not supply those bridge-measurement functions.
| Channels | Listed nominal sensitivity |
|---|---|
| Fx / Fy | 1.5 ±0.3 mV/V |
| Fz | 1.3 ±0.3 mV/V |
| Mx / My | 1.4 ±0.3 mV/V |
| Mz | 1.2 ±0.3 mV/V |
The listed reference excitation is 10 V AC/DC, with a maximum of 15 V AC/DC. Obtain the circuit and conditioner requirements for the delivered assembly before choosing a supply; the maximum is not a normal operating recommendation. Use the individual channel calibration rather than applying one nominal sensitivity to all channels.
Request the connector and terminal schedule, channel identities, sign convention, calibration method and any coupling matrix that is included. Agree where corrections and coordinate transformations are applied. Sampling rate, synchronization, filtering, dynamic response and software support need explicit confirmation for a moving test; static ratings do not establish them.
Distinguish a joint-reaction measurement from six-axis measurement
The METRAVON MV-LC0226 is a load pin with a bridge output for its defined support and loading arrangement. Its published information does not establish six separately calibrated force and moment outputs.
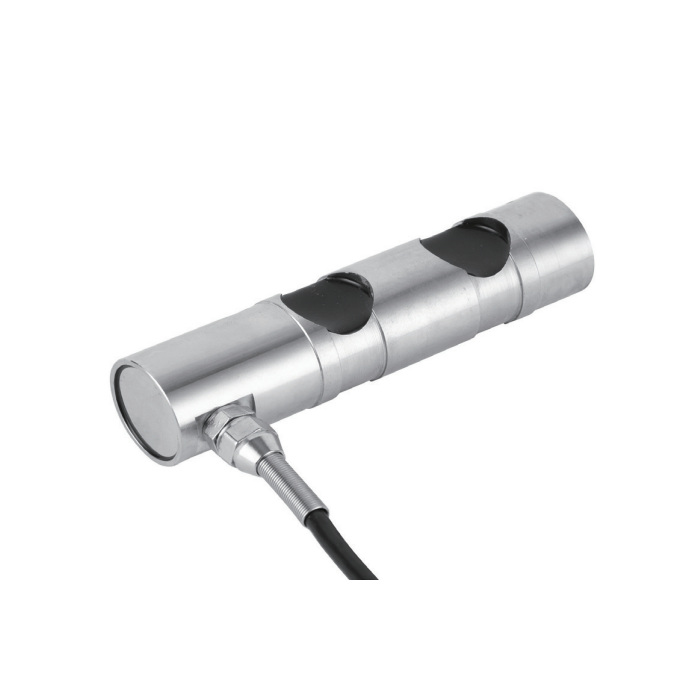
If the task is one reaction in a reviewed pin joint, that load pin may address the narrower requirement. If the project needs Fx, Fy, Fz, Mx, My and Mz separately, assess the documented MV-LC0241 assembly and acquisition chain. These are different measurement tasks; matching a mounting location or a broad force rating does not make the products interchangeable.
Agree the demonstration before requesting a final quotation
Define reference load cases with known directions and application points. Include the final adapters and record all six channels together. Check sign, units, zero return and the moment expected from the known geometry. Review responses on the other channels against the agreed calibration and correction method. Six changing numbers alone are not six-axis calibration evidence.
For changing loads, use the planned acquisition settings and loading sequence. Record channel timing and the conditions under which the reference comparison is valid. A slow static demonstration cannot establish peak capture during a faster machine cycle. Set acceptance limits from the project requirement and the agreed test uncertainty, rather than inventing a universal tolerance from the capacity table.
Questions about the sensor and data system
Q1. Can six ordinary PLC inputs establish a six-axis measurement?
Input count alone is insufficient. The mechanical sensor must resolve the six components, and the acquisition chain must excite and read the bridges, apply the agreed calibration and preserve timing where the load changes. Compare the exact input functions and calibration deliverables before specifying a PLC connection.
Q2. Can force and moment values be selected from different rating rows?
The published rows are matched combinations. Request a review if the required force and moment envelope falls outside a listed set; do not construct a new rating by mixing rows. Include simultaneous loads and fixture offsets in that request.
Q3. Does the product include a digital network interface or calibration matrix?
The cited product information identifies mV/V bridge outputs and asks for confirmation of the acquisition and calibration scope. Specify any required 4-20 mA, RS485, Modbus RTU or other controller interface separately. Obtain written details of the supplied conditioner, software and correction data rather than assuming they are built in.
Q4. Does moving the tool require a new calibration?
A changed tool or adapter requires review of the loading geometry, coordinate transformation and validation scope. Whether a new sensor calibration is needed depends on what changed and the existing evidence. At minimum, verify the final fixture with known load cases at the required application points.
Q5. What should be sent with an MV-LC0241 enquiry?
Send the complete force and moment envelope, candidate matched rating row, fixture and coordinate drawings, peak and cyclic loads, minimum useful signal, and acquisition hardware. State the required sampling behaviour and calibration deliverables so the sensor, electronics and acceptance work can be quoted as a defined scope.
Summary
Use MV-LC0241 as the documented six-axis starting point, then confirm the matched rating set, loading geometry, six bridge channels and calibration scope. Keep a load-pin enquiry separate when only a joint reaction is needed. Send the drawings and measurement requirements through the METRAVON contact page. Compare the load cell structures if fewer force components are required.
