


 Chinese
 Spanish
 Russian
 Portuguese
 French
 German
 Indonesian
 Thai
 Vietnamese
 Arabic
 Italian
 Turkish
 Polish
 Japanese


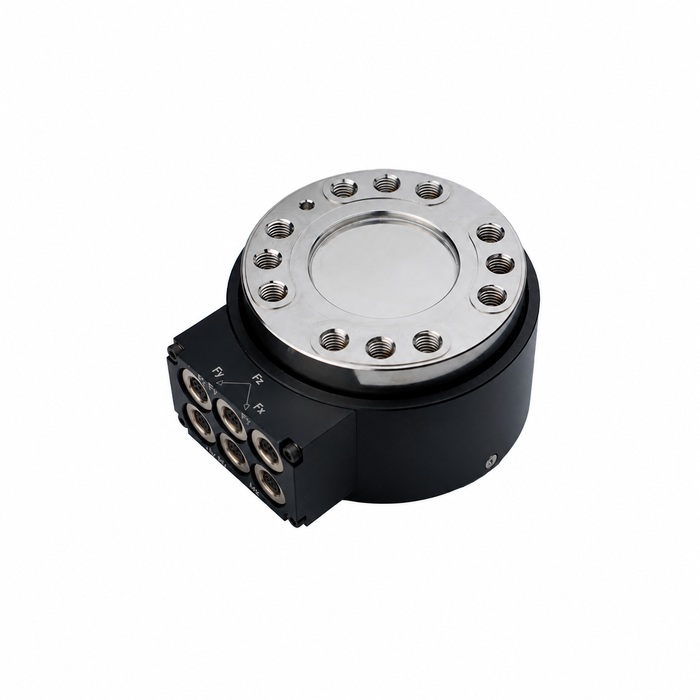
A robot wrist sensor measures more than contact with the workpiece. Tool weight, offset, acceleration and cable forces also reach the measuring element. Robot force-torque sensor selection must separate those contributions and establish how the controller will use the result. A matching flange and six changing signals do not demonstrate a usable force-control installation.
Robot force-torque sensor selection begins with the task
State whether the system records process forces, adjusts motion during contact, detects abnormal contact or performs a protective function. These are different requirements. A sensor that supports logging may lack the confirmed timing and controller integration needed for closed-loop force control.
Describe approach, contact, working motion and withdrawal. Identify the force or moment used to make each decision and the expected event duration. Include tool changes, workpiece variation and the relevant robot poses. This gives a basis for selecting range and testing the complete task rather than judging the sensor from one stationary push.
Review the load at the wrist, including tool offset
List the sensor, adapters, tool and carried workpiece in the robot payload assessment. For the sensor-load calculation, identify which components are on the tool side of the sensing element. Their weight and acceleration can add force and moment before contact begins.
An illustrative perpendicular force of 100 N acting 0.20 m from the sensor origin creates a 20 N m moment. This follows from force times perpendicular lever arm; it is not a recommended process load. A long adapter can therefore make moment capacity limiting even when the force is modest.
Review the relevant poses and motion cases with the robot's own wrist limits. Sensor overload limits and robot payload limits answer different questions. Adding a sensor also changes stack height and may affect reach, cable motion and fixture clearance. Neither the sensor nor its adapter should be assumed to provide collision protection.
Read the MV-LC0241 ranges as matched configurations
The METRAVON MV-LC0241 reference provides three range sets. The smallest listed set is shown below as a complete group; it is not a low-force performance guarantee.
| Component | Smallest listed range set | Check for the proposed tool |
|---|---|---|
| Fx / Fy | 2 kN | Include lateral contact and motion loads, then check the smallest useful lateral increment. |
| Fz | 10 kN | Include the relevant axial preload and contact load without assuming fine-force resolution. |
| Mx / My | 150 N m | Calculate bending moments from the tool centre of mass and contact offset. |
| Mz | 150 N m | Include twisting contact and the required moment direction. |
Do not mix the axial range from one set with the moment range from another when ordering. Obtain the allowable combined-load conditions, mounting requirements and calibration information for the exact configuration. The public range table alone does not establish that every channel can reach its limit simultaneously.
The reference sensitivities also differ by component: 1.5 mV/V nominal for Fx/Fy, 1.3 for Fz, 1.4 for Mx/My and 1.2 for Mz. The documented excitation is 10 V AC/DC, with 15 V AC/DC as the maximum. Specify compatible conditioning for the actual supplied arrangement. Do not apply one gain value to all six channels.
Commission coordinates and gravity before contact control
Mark the sensor axes and identify the tool coordinate frame and reporting origin. Check signs using known loads in controlled poses. Rotating coordinates and moving the moment origin are separate operations; both must match the robot task.
Zeroing in one pose subtracts the reading in that pose. It does not by itself compensate tool gravity as the wrist rotates. Establish the mass and centre-of-mass information needed by the selected compensation method, then verify unloaded readings through the permitted orientations.
Retain sensor-origin values for overload assessment alongside any tool-point results. A transformed moment can be small at the contact point while the physical sensor still carries a substantial moment from the offset. Compensation changes the reported data, not the mechanical load.
Check the data path to the robot controller
MV-LC0241's documented outputs are low-level bridge signals. The available reference does not establish a ready-to-use robot driver, EtherCAT interface, controller update rate or communication latency. Request those details for the proposed acquisition package and robot controller before committing to force-control integration.
Specify channel synchronisation, filtering, output units, validity status and the response to stale or missing data. Verify them at the point where the robot uses the measurement. A fast nominal sample rate is not enough if communication or filtering adds unacceptable delay.
Commission with the approved test procedure: verify reference loads and signs, inspect compensation without contact, then test the intended task under controlled conditions. Record adapter drawings, calibration identification, tool properties and controller settings. Recheck the affected tests after changes to the tool, dress pack, adapters or processing software.
Questions from robot integration projects
Q1. Is this automatically suitable for gentle assembly because it measures six components?
No. Establish the required force increments and compare them with the actual range, noise and calibrated performance of the complete chain. The smallest published range set is still substantial. Ask for evidence at the task's working loads rather than interpreting six-axis capability as fine-force sensitivity.
Q2. Can its output be used as a safety-rated collision signal?
Not on the basis of the measurement specifications alone. A protective function needs its own documented architecture, assessment and validation. Keep ordinary process monitoring separate unless the complete system has been approved for the intended protective role.
Q3. What information should be supplied for a feasibility enquiry?
Send the robot and controller identification, tool mass and centre of mass, adapter drawing, task sequence, per-axis loads, required increments and timing. Include the acquisition proposal through METRAVON enquiries. The multi-axis selection guide provides the channel and calibration checks to complete before integration.
Summary
Assess wrist loads, signal quality and controller compatibility together. MV-LC0241 documents six measured components, but that does not establish suitability for every robot or contact task. A useful offer identifies the exact range set and acquisition arrangement, with unresolved timing, mounting and validation requirements made explicit before purchase.
