


 Chinese
 Spanish
 Russian
 Portuguese
 French
 German
 Indonesian
 Thai
 Vietnamese
 Arabic
 Italian
 Turkish
 Polish
 Japanese


Motor power is useful background for rotary torque sensor selection, but it does not describe every load the sensor will encounter. Starting, braking and a stalled mechanism can produce conditions very different from steady operation. Specify the torque and speed together, then check whether the proposed sensor can be installed in the actual driveline without carrying unintended shaft loads.
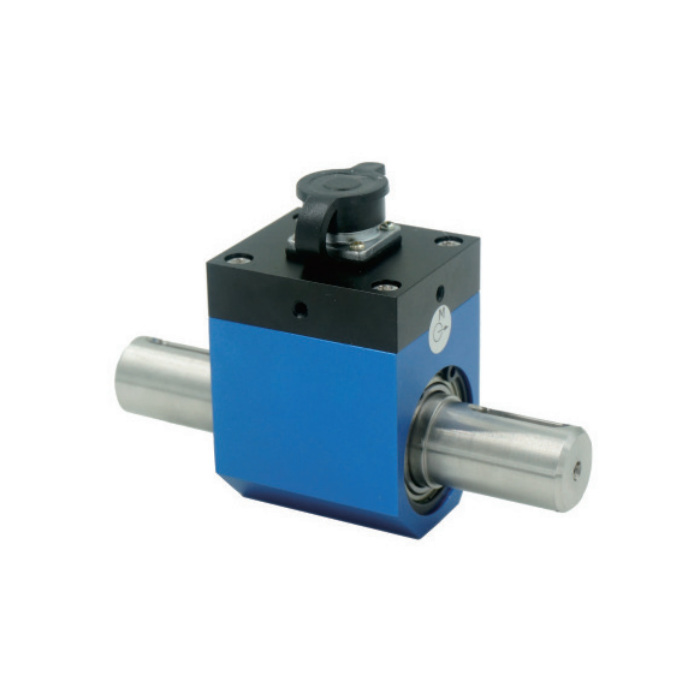
Rotary torque sensor selection needs a torque-speed envelope
List the normal torque interval, the smallest change to be measured, the largest expected transient, both rotation directions and maximum operating speed. Give the duration and repetition of peaks where known. The mechanical review also needs abnormal conditions such as a blocked output or a drive trip; these must not be treated as ordinary calibration points.
For steady shaft power, torque in N m is approximately 9550 times power in kW divided by speed in rpm. An illustrative 2 kW transmitted at 1000 rpm corresponds to about 19.1 N m. This calculation uses power at the shaft being measured. A motor nameplate or electrical input value is not necessarily that shaft power.
The equation does not determine stall torque at zero speed and does not bound starting or reversing peaks. Obtain the relevant drive and load information before selecting the range. An oversized range can leave too little signal for a friction or efficiency test, while a range chosen only from normal power may not survive the actual duty.
What the MV-LC0148 reference establishes
| Item | Reference | Purchasing implication |
|---|---|---|
| Capacity family | 0.1-500 N m, in listed discrete ratings | Identify the exact rating; the family range is not one selectable software span. |
| Nominal output | 1.0-1.5 mV/V | Request the supplied sensitivity and matching conditioner requirements. |
| Excitation | 12 V recommended; 15 V maximum | Check the actual electrical configuration rather than using the maximum as the normal setting. |
| Published maximum speed | Up to 4000 rpm | Confirm allowed continuous operation at the required torque, speed and installation conditions. |
The METRAVON MV-LC0148 reference drawing separates 0.1-100 N m and 200-500 N m dimensional groups. A higher capacity can therefore require different shaft connections and space. Ask for the approved drawing before purchasing couplings or machining a base.
The published maximum-speed statement is not a complete continuous-duty envelope. Likewise, a statement about bidirectional torque output does not specify response bandwidth, a speed-output channel or a controller protocol. These requirements must be confirmed for the offered configuration.
Review the shaft line before ordering couplings
Draw the motor, sensor, driven machine, supports and couplings. Identify shaft centre heights, keyways, axial clearances and the loads carried by each bearing. The transducer is not a general-purpose flexible coupling and should not be used to pull misaligned shafts into position.
Couplings must suit torque, speed and the installation's permitted misalignment. Their selection can also affect torsional behaviour. Ask for allowable radial and axial loads and the required mounting method where these are not stated in the public reference. Do not infer bearing load capacity from the torque rating.
Rotating components need the equipment's approved guarding and safe installation procedure. Any change to shaft lengths, couplings or supports belongs in the driveline review. A satisfactory static torque reading is not evidence that the assembly is suitable to run at its intended speed.
Decide which torque event the data must preserve
A mean running-torque measurement and a short peak measurement impose different requirements. Define the event duration and where the result is used. Ask for the complete sensor-and-conditioner response, sampling and filtering information; a fast PLC scan cannot recover a peak already removed upstream.
For power or efficiency calculations, torque and speed must describe the same operating interval and shaft location. If speed comes from another device, check its timing and scaling. Do not assume MV-LC0148 provides a speed signal merely because it operates on a rotating shaft.
The documented mV/V output needs compatible measurement electronics. Confirm the stationary connections, supply, signal format, calibration and final interface in the offer. Keep clockwise and counter-clockwise sign conventions consistent from the sensor to the logged result.
Questions before a test-rig purchase
Q1. Does a static calibration prove performance while rotating?
No. It checks the measurement under the stated calibration conditions. Verify the completed rig at the required operating conditions, including zero behaviour, vibration and the useful torque interval. Use a suitable reference method and record speed and signal settings with the results.
Q2. Can the same sensor cover low-torque research and occasional high-load tests?
Only if its range and the complete electronics meet both requirements. Calculate the signal associated with the smallest useful torque and check it against observed noise and drift. Separate configurations may be necessary; software display resolution does not recover measurement information that the chain cannot resolve.
Q3. What should accompany a request for a quotation?
Send the torque-speed cases, shaft and mounting drawings, coupling proposal, required event timing and data interface through the METRAVON contact page. State whether the quotation includes couplings, conditioning and calibration. Identify missing continuous-duty or mechanical-load data before approving the configuration.
Summary
Choose the rotary sensor from the actual torque-speed duty and the shaft assembly, not motor power alone. For MV-LC0148, confirm the exact capacity, drawing and electrical configuration, then verify the required measurement during operation. Maximum speed and static calibration are useful references, but neither replaces the test-rig acceptance plan.
